Conor Mulligan - Engineering Portfolio

Create Your First Project
Start adding your projects to your portfolio. Click on "Manage Projects" to get started


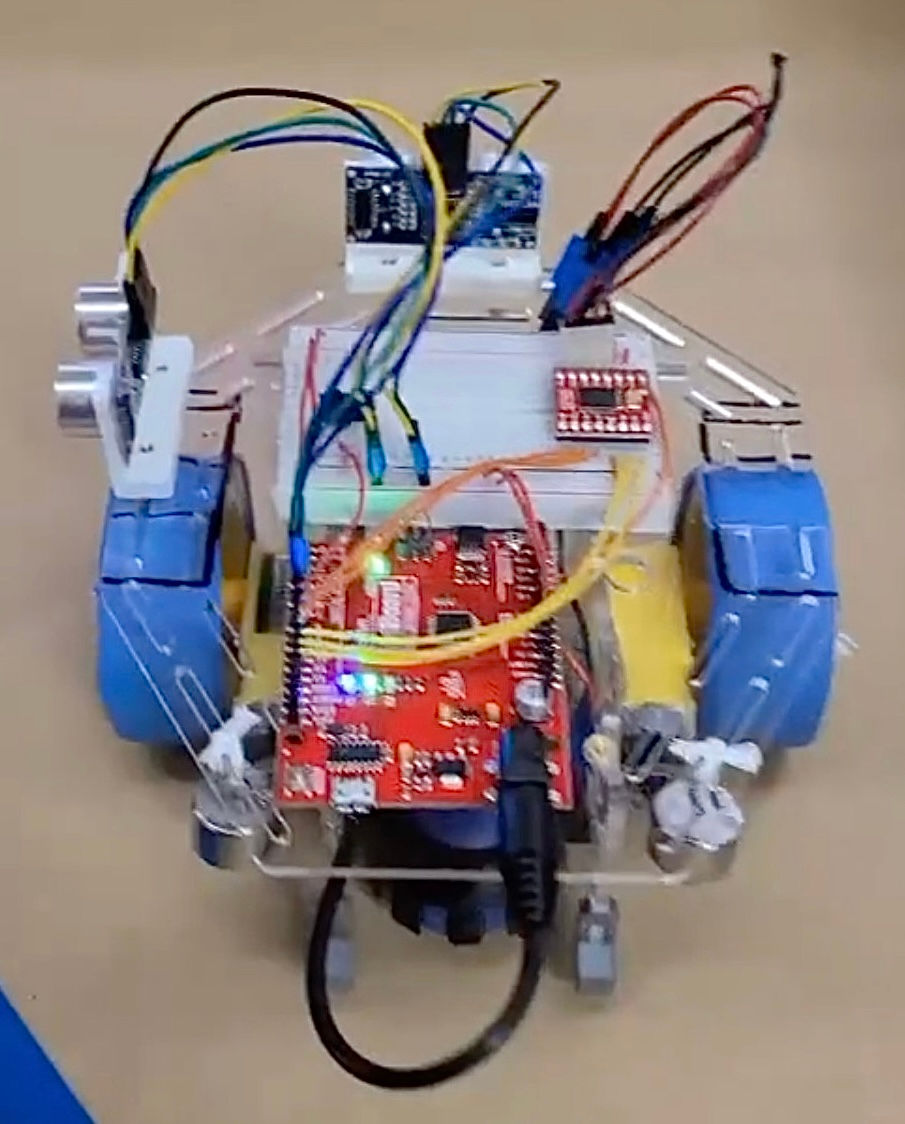
Autonomous Environmental Survey Robot
Project Overview:
- Designed and built a manually operated robot for remote environmental monitoring in potentially hazardous areas.
- Developed the system to collect real-time air quality, toxic gas, and temperature data while reducing the need for direct human exposure.
- Combined a rugged mobile chassis, environmental sensors, wireless communication, and a custom visual interface for remote data review.
Design Steps:
- Built a four-wheeled robot chassis designed to handle uneven surfaces, small obstacles, and rough indoor terrain.
- Integrated environmental sensors to measure gas concentration, air quality, and temperature in real time.
- Added Bluetooth communication to transmit sensor data wirelessly to a laptop.
- Developed a custom display interface to present environmental readings clearly during operation.
- Built a manual control system using joysticks for movement, steering, and speed adjustment.
Challenges:
- Maintaining stable Bluetooth communication between the robot and laptop during operation.
- Designing a chassis that was durable enough for rough surfaces while still being compact and manageable.
- Integrating sensors, wiring, controls, and power components into a functional mobile platform.
- Calibrating sensor readings to provide useful real-time feedback under changing environmental conditions.
Results:
- Successfully demonstrated remote operation and real-time environmental data collection.
- Transmitted sensor readings wirelessly to a laptop for live monitoring.
- Built a working prototype that showed how a low-cost mobile platform could support environmental assessment in simulated hazardous conditions.
Engineering Skills Demonstrated:
- Mechanical Design: Designed and assembled a durable mobile chassis using 3D-printed and prefabricated components.
- Electronics Integration: Wired environmental sensors, control hardware, and Bluetooth communication components into a working system.
- Programming: Developed Arduino code to process sensor data, support manual control, and display readings in real time.
- Systems Integration: Combined mechanical, electrical, and software elements into a complete functional prototype.
- Testing and Troubleshooting: Addressed sensor calibration, wireless communication, and control issues during system development.